
JINSAN and Xiaoling: Choosing an AI Robot Configuration
Compare JINSAN full-body AI companions and the Xiaoling V3 research platform, from head movement and voice options to hardware and software considerations.
Practical guides and perspectives on humanoid robotics.
Compare JINSAN full-body AI companions and the Xiaoling V3 research platform, from head movement and voice options to hardware and software considerations.
A practical framework for scoping and evaluating a commercial reception pilot—from the first visitor task and fixed-versus-mobile choice to test questions, staff handoff and a go/no-go review.
A practical buyer guide for U.S. nursing homes and senior-care organizations assessing social robots, confirmed interaction features, health-sensing evidence, privacy, and workflow fit.
Learn how to compare a robot SDK, API integration and custom development when planning an AI humanoid project. Use this framework to define scope before requesting a quote.
A robot vision system is more than a camera. Learn how perception models, depth, touch, proximity and joint feedback work together in humanoid robots—and what to ask before treating a research direction as a product capability.
A practical introduction to electronic skin, flexible tactile sensors, pressure mapping, and the engineering choices behind touch-aware robots.
A practical guide to the face, hands, tactile sensing and control layers behind bionic humanoid robots and more natural human–robot interaction.
A practical guide to defining an AI companion robot configuration: interaction goals, physical embodiment, interfaces, validation, privacy questions, and quote-ready inputs.
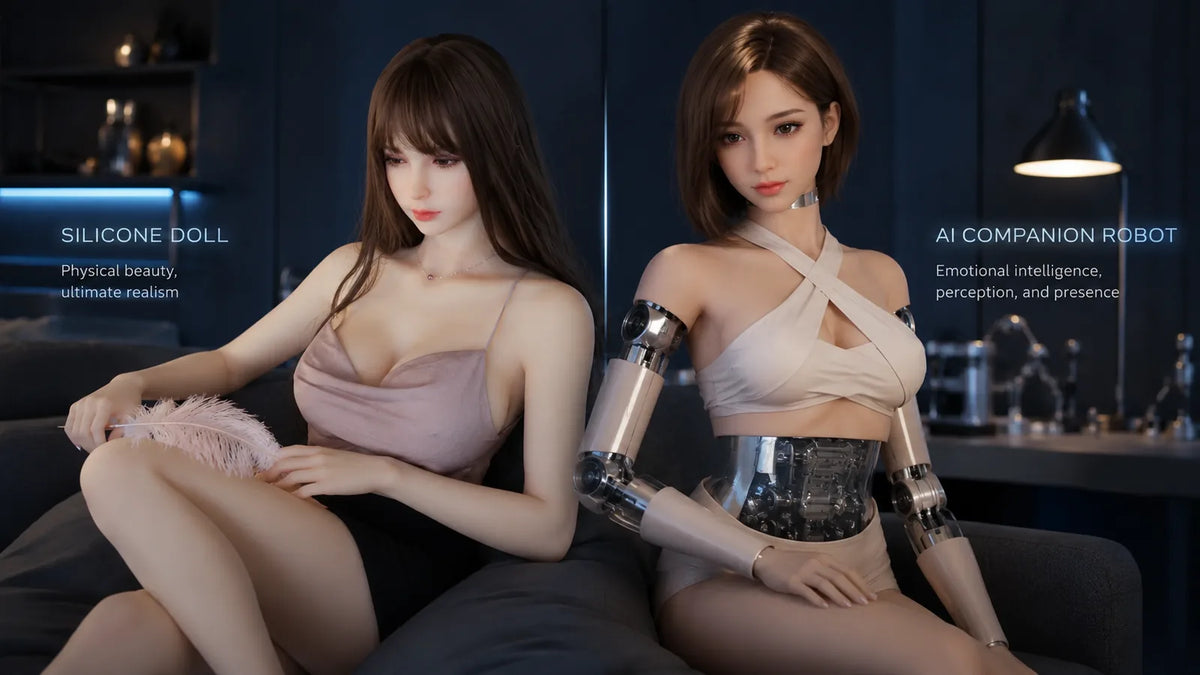
Compare silicone dolls, AI emotional dolls, and AI companion robots by materials, interaction, AI head upgrades, care, pricing, and long-term ownership.